A Coordinated Electric System Interconnection Review—the utility’s deep-dive on technical and cost impacts of your project.
Challenge: Frequent false tripping using conventional electromechanical relays
Solution: SEL-487E integration with multi-terminal differential protection and dynamic inrush restraint
Result: 90% reduction in false trips, saving over $250,000 in downtime
The three operating regions you have to design to
| Device | Output vs voltage | Response | Best suited to | Main limitations |
|---|---|---|---|---|
| Mechanically switched capacitor or reactor | Proportional to voltage squared | Seconds; discrete steps; limited switching operations per day | Steady-state reactive supply, voltage profile, loss reduction | No dynamic capability; step voltage change on switching; capability collapses when most needed |
| Static var compensator | Capacitive branches proportional to voltage squared | A few cycles; continuously controllable | Continuous control where cost matters and deep voltage support is not the driver | Square-law capability loss; harmonic filters are part of the plant and interact with the network |
| STATCOM | Approximately proportional to voltage — constant current capability | One to two cycles closed loop; converter response faster still | Voltage stability margin, weak interconnections, fast disturbance recovery, flicker and unbalance compensation | Higher capital cost; converter losses; adds a converter and its control dynamics to the network |
| Synchronous condenser | Governed by machine capability and excitation | Excitation response in the hundreds of milliseconds; inherent inertial response instantaneous | System strength and inertia, short-circuit contribution, black start support | Rotating plant with maintenance and losses; slower controlled response than a converter |
| STATCOM with energy storage | Reactive as a STATCOM, plus real power within the storage rating | As STATCOM for reactive; real power limited by storage | Where a real power deficiency is part of the problem | Cost and complexity of the storage; different failure and maintenance profile |
| Service area | What we do for SST campuses | Typical deliverables |
|---|---|---|
| Grid interconnection | Site screening, large-load applications, independent studies, utility and RTO coordination in ERCOT, NYISO, PJM and other markets | Screening reports, application data packages, load flow, contingency and stability studies, study review memos |
| EMT modeling | Model requirements, vendor model review, campus aggregation, ride-through, weak-grid, control interaction and load-oscillation studies | EMT model specifications, model acceptance reports, PSCAD study reports, SCR screening |
| MV/MVDC system studies | AC and DC short-circuit, DC protection philosophy, AC protection, arc flash, grounding, insulation coordination | Study reports, protection philosophy documents, settings files, arc flash labels, interface control documents |
| Power quality | Emission requirements, frequency scans, IEEE 519-2022 compliance, filter sizing, flicker assessment | Harmonic study reports, filter specifications, monitoring plans |
| Substation and transmission design | HV/EHV substations, MV collectors, transmission lines, utility interface protection | Physical and electrical drawing packages, specifications, bills of material, protection and control design |
| NERC compliance | Registration and applicability, ride-through requirements, model validation, monitoring, compliance programs | Applicability assessments, compliance programs, evidence packages, model validation reports |
| Owner's engineer and QA/QC | SST, storage and substation specifications, design reviews, FAT and SAT plans and witnessing, multi-unit QA | Specifications, review comments, test plans, witness reports, due diligence reports |
| Onsite generation and BESS | Role definition and sizing, DC bus control architecture, fire and code compliance coordination, performance testing | Sizing studies, control architecture documents, specifications, test procedures |
Storage and generation
| Term | Meaning |
|---|---|
| AFE | Active front end. The actively switched AC/DC stage of an SST that connects to the MV grid and sets its grid behavior. |
| Aggregated model | A model in which many converters are represented by a smaller number of equivalent converters to make campus-scale simulation practical. |
| Arc flash | The release of energy from an electric arc fault, assessed as incident energy at a working distance to set PPE and safe work practices. |
| BESS | Battery energy storage system. |
| Blocking | Turning off all converter switches so the converter stops feeding current, used to limit DC faults. |
| Composite load model | A positive-sequence load model that combines several load types, such as motors, electronics and static loads. |
| DAB | Dual active bridge. An isolated DC/DC converter topology with active bridges on both sides of a high-frequency transformer. |
| DC-link | The internal DC capacitor bank between converter stages. |
| EMT | Electromagnetic transient simulation. Time-domain simulation with microsecond time steps, used to study fast converter and network behavior. |
| FAT | Factory acceptance test. |
| Grid-forming | A converter control mode that sets its own voltage and frequency reference rather than following the grid's, providing support to weak grids. |
| HIL | Hardware-in-the-loop testing, in which a real controller is tested against a real-time simulation. |
| IBR | Inverter-based resource. Generation or storage connected to the grid through power electronics. |
| Insulation coordination | Matching the insulation strength of equipment to the voltage stresses the system produces, with surge protection where needed. |
| ISC/IL | The ratio of available short-circuit current to maximum demand load current at the point of common coupling, used to set IEEE 519 limits. |
| ISOP | Input-series, output-parallel. A modular converter arrangement that shares a high input voltage across cells in series and combines their outputs in parallel. |
| Large load | A load large enough to affect transmission system reliability. Definitions vary, for example 75 MW and above under Texas SB 6, or loads above 20 MW in the federal rulemaking proposal. |
| LVDC | Low-voltage DC, such as 800 VDC or ±400 VDC rack distribution. |
| MFT | Medium-frequency transformer. The compact isolation transformer inside an SST, operating at kilohertz frequencies. |
| MMC | Modular multilevel converter. A converter built from many submodules with their own capacitors, producing a stepped multilevel waveform. |
| MVDC | Medium-voltage DC distribution, roughly 1 kV to 35 kV DC in common usage. |
| OE | Owner's engineer. An independent engineer representing the owner's technical interests. |
| PCC / POI | Point of common coupling / point of interconnection, where the campus connects to the utility system and where compliance is usually assessed. |
| PLL | Phase-locked loop. The control element that tracks grid voltage phase and frequency. |
| Positive-sequence model | A fundamental-frequency, balanced dynamic model used in PSS®E, PSLF and similar tools. |
| Ride-through | The ability to stay connected and keep operating during and after a grid disturbance within defined limits. |
| SAT | Site acceptance test. |
| SCR | Short-circuit ratio. Available short-circuit power divided by converter rating, a measure of grid strength. |
| SiC | Silicon carbide, a wide-bandgap semiconductor material that allows higher voltage, higher frequency switching. |
| SST | Solid-state transformer. A power electronic converter with a high-frequency isolation stage that replaces a 60 Hz transformer and rectifier chain. |
| Supraharmonics | Emissions in the 2 kHz to 150 kHz range, above the range covered by most harmonic limits. |
| TDD | Total demand distortion. Harmonic current distortion relative to maximum demand current, used in IEEE 519. |
| WSCR | Weighted short-circuit ratio. An SCR screen that accounts for several inverter-based plants sharing a network area. |
Links were current at publication (November 2026). Large-load rules, NERC actions and standards editions are changing quickly, so confirm current versions before relying on them.
Large-load reliability and NERC
- NERC Publishes Incident Review and Guidance on Voltage-Sensitive Large Load Integration, NERC
- Reliability Insights: Large Computational Load Risks Due to Voltage Sensitivity, NERC, September 2026
- NERC Seeks to Address Reliability Impacts from Large Load Integration, NERC presentation to FERC, April 2025
- NERC issues Level 3 Alert to address immediate risks data center loads pose to the grid, Renewable Energy World, May 2026
- NERC Voltage-Sensitive Loads, Keentel Engineering
Federal and state large-load rules
- FERC Docket RM26-4, Interconnection of Large Loads, FERC
- FERC Establishes Proceeding to Consider DOE Directive on Large Load Transmission Interconnection Rulemaking, McGuireWoods, October 2025
- Texas Senate Bill 6 Ushers in Major Overhaul of Large Load Interconnection and Grid Access Rules, Bracewell, July 2025
- Public Utility Commission of Texas Issues Proposed Rules for Large Load Interconnections, Foley & Lardner, March 2026
Solid-state transformers and DC data center power
- Solid State Transformer project, Open Compute Project
- Novel Solid-State Transformer Supports 800-V DC Power in AI Data Centers, Electronic Design
- How SSTs are Reshaping Data Center Infrastructure, Microchip Technology
Standards referenced (consult the publisher for the current edition)
Step 5 — options. Replacing or retrofitting the drives with active-front-end or 18-pulse units at about 5% THDi gives a TDD of about 1.5%. An active harmonic filter sized for the 5th and 7th could achieve a similar result at the facility level. A passive 5th-harmonic tuned filter would also work but must be checked for resonance with the utility system and with any future capacitors.
What this means for you.
The same drives can be compliant on a strong system and non-compliant on a weak one. Ask your utility for the maximum short-circuit current at the PCC early in design. If the ratio is below 50, plan for low-harmonic drives or filtering from the start; it is much cheaper than retrofitting.
9. Inverter-based resources: solar, storage and wind
Solar PV, battery energy storage and full-converter wind turbines use pulse-width-modulated inverters with output filters. They are generally low-distortion sources. IEEE Std 1547-2018 (distribution-connected resources) and IEEE Std 2800-2022 (transmission-connected resources) limit their current distortion — total rated-current distortion (TRD) of 5% with individual limits by order, measured against rated current rather than present output. In practice, quality inverters measure 1–3% at rated output.
Three cautions apply:
- Percentages rise at low output. At 10% of rated output a 2% distortion (of rated current) looks like 20% THD. Limits referenced to rated current, like TDD, avoid this trap.
- Inverters change the system's impedance. Plant collector cables, inverter output filters and capacitor banks add capacitance. They can create resonances near the 5th to 13th harmonics on the 34.5 kV collector or at a 138 kV, 230 kV or 345 kV point of interconnection, amplifying background distortion that the plant did not create.
- Background distortion matters. Inverters can absorb or amplify existing voltage distortion depending on their control design. Utilities increasingly require harmonic impedance studies for new plants, sometimes using electromagnetic transient (EMT) simulation.
Keentel's articles on harmonic resonance and on
weak-grid inverter stability cover these interactions in depth.
10. Data centers and other electronic facilities
Data centers are a special case because almost all their load is electronic. Points to check:
- UPS rectifiers. Double-conversion UPS units with IGBT rectifiers typically draw less than 5% THDi at rated load, rising at low load. Older six-pulse or 12-pulse thyristor UPS rectifiers may need input filters.
- Server and network power supplies. Modern units with active power factor correction have low 3rd harmonic. Legacy equipment does not. Measure a representative panel rather than assuming.
- 208Y/120 V and 415Y/240 V distribution. Check neutral current and transformer K-factor as in Sections 4 and 7.
- Generator operation. Test UPS and generator compatibility at the actual load level. Generator THDv can be three to four times the utility THDv for the same load.
- Cooling plant. Chiller, pump, fan and cooling distribution unit drives often contribute more low-order harmonics than the IT load. Specify low-harmonic drives where the facility is large relative to the utility source.
- Large-load interconnection. Utilities and grid operators now treat large data centers as high-impact loads. Harmonic studies and power quality monitoring are increasingly part of interconnection requirements, alongside ride-through and dynamic studies.
11. How a harmonic study is done
A harmonic study answers four questions: How much harmonic current will the facility inject? What voltage distortion will it cause? Will any resonance amplify it? What is the cheapest reliable fix? Keentel's typical workflow:
- Gather data. Single-line diagram; utility short-circuit data (maximum and minimum) at the PCC; utility background distortion if known; transformer impedances; cable lengths; capacitor banks and filters; drive, UPS and inverter data sheets with harmonic spectra.
- Measure existing conditions. For existing facilities, install class-compliant power quality meters at the PCC and key buses for at least one week, capturing 10-minute and 3-second data up to the 50th harmonic.
- Build the model. Represent sources as harmonic current injections and the network as frequency-dependent impedances, including transformer phase shifts that can cancel 5th and 7th harmonics between delta-delta and delta-wye units.
- Run a frequency scan. Plot driving-point impedance versus frequency at each important bus to find resonances, for all credible system configurations (tie breakers open/closed, capacitor steps in/out, generator versus utility).
- Run harmonic load flow. Calculate harmonic currents and voltages and compare them with IEEE 519 at the PCC and with equipment limits (IEEE 18 for capacitors, C57.110 for transformers) inside the facility.
- Design mitigation. Compare options for performance, cost, losses, footprint and future flexibility.
- Verify. Measure again after installation and document compliance with the statistical criteria.
12. Fixing harmonics: options compared
From Nadir to Nominal: The Four Stages of Frequency Response After a Generation Loss in US Interconnections
November 05, 2026 | Blog
Part A — Frequency Response at a Glance
A large generating unit trips. In the first fraction of a second nothing else on the system has changed: the same load is still connected, the same generators are still running, and the lost megawatts must come from somewhere. They come from the rotating mass of every synchronous machine in the interconnection, which slows down. Frequency falls.
Over the next ten minutes, a chain of responses takes over, each faster to arrive than the next and each with a different job. Inertia limits how fast frequency falls. Primary frequency response from governors, inverter-based resources and load arrests the fall and holds frequency at a new, lower level. Secondary control — automatic generation control (AGC) — returns frequency to 60 Hz and restores scheduled interchange. Tertiary actions — reserve deployment, re-dispatch and unit commitment — replace the reserves that were used up, so the system is ready for the next contingency.
That chain answers a question that confuses many people outside system operations: can frequency recover to 60 Hz while the lost generator is still offline? Yes. Frequency recovery does not mean the failed unit came back. It means other resources have replaced its output — first automatically and partially, then deliberately and completely. The generation shortfall at the failed plant persists; the system-wide imbalance does not.
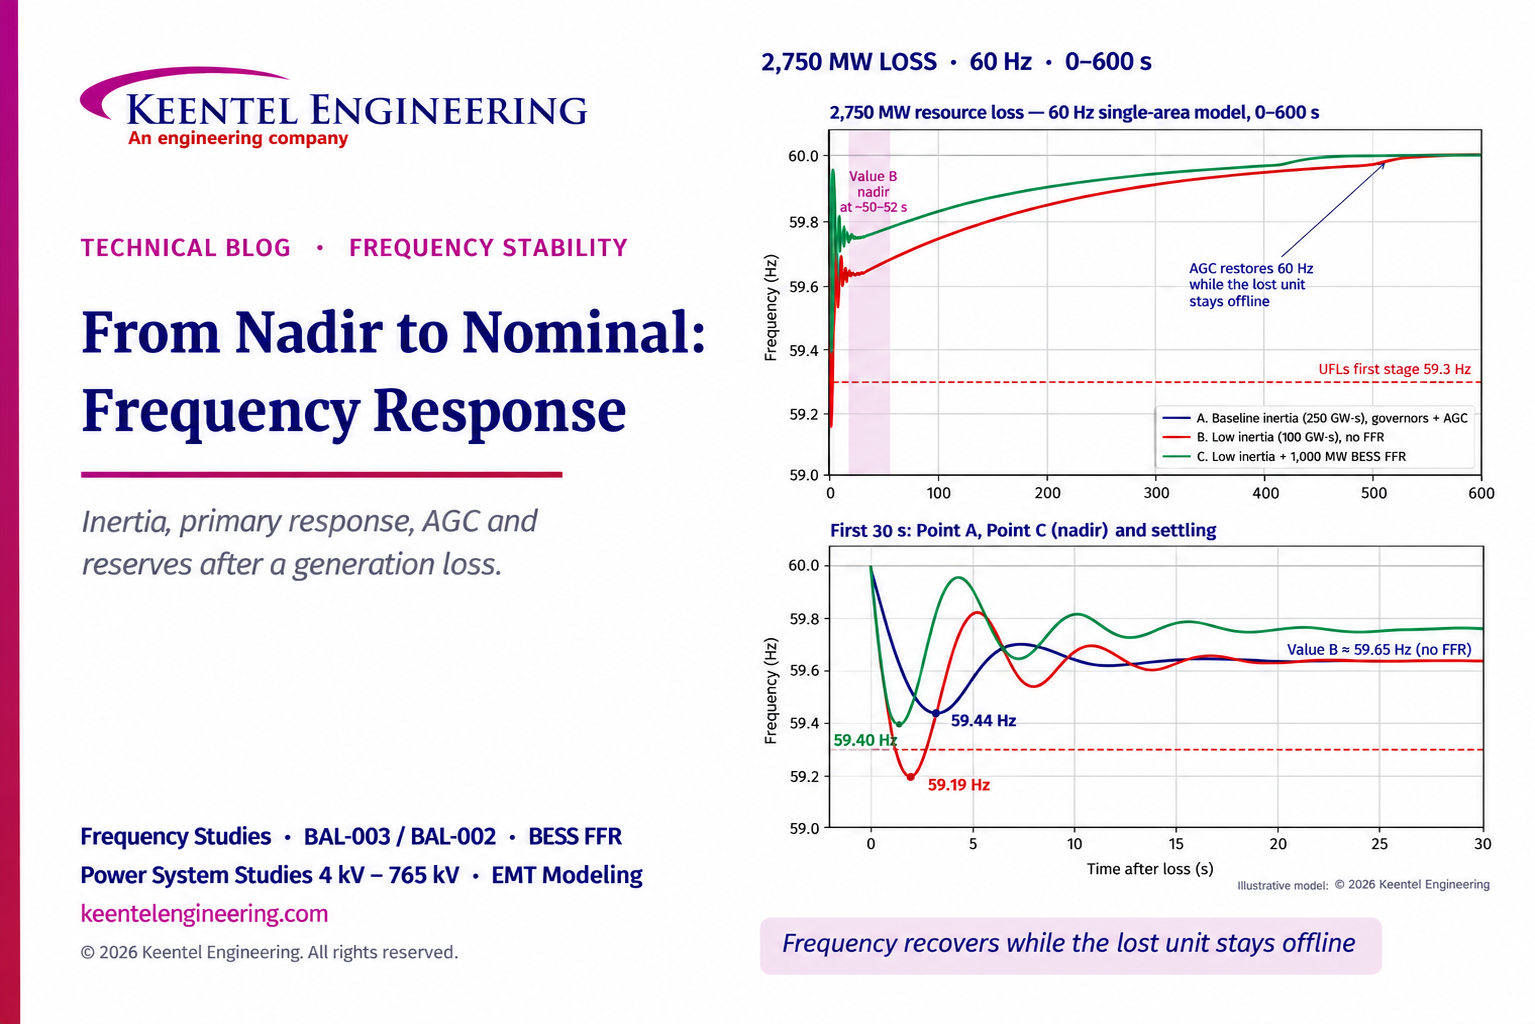
This guide walks through that chronology in US terms: the four interconnections, the NERC BAL standards that define each stage, the measurement points that NERC uses to grade frequency response (Point A, Point C and Value B), the area control error that drives AGC, and the role of solar, wind and battery storage at each stage. Keentel Engineering's own single-area simulation of a 2,750 MW resource loss makes each stage concrete.
Keentel's companion article on grid inertia and RoCoF covers the swing equation, inertia constants and synthetic inertia in depth. This article focuses on the complete response chain — from the first second to the tenth minute — and on how US standards measure and enforce it.
The four stages in one table
| Stage | Time frame | What acts | What it does | US standard or product |
|---|---|---|---|---|
| 1. Inertial response | Instantaneous, from t = 0 to the nadir | Kinetic energy of synchronous machines and motor loads | Limits the rate of change of frequency (RoCoF); buys time | No direct standard; monitored by operators (ERCOT tracks inertia in real time) |
| 2. Primary frequency response | About 0.5 s to 30 s | Governors, IBR droop controls, fast frequency response, load damping | Arrests the decline (nadir, Point C) and settles frequency (Value B) | NERC BAL-003-2; FERC Order No. 842; ISO products such as ERCOT FFR and Responsive Reserve |
| 3. Secondary control (AGC) | About 30 s to 10–15 minutes | AGC signals to regulating units and deployed contingency reserves | Drives area control error (ACE) to zero, returning frequency to 60 Hz and interchange to schedule | NERC BAL-001-2 (CPS1, BAAL) and BAL-002-3 (15-minute recovery) |
| 4. Tertiary control and reserve restoration | About 10 minutes to 90+ minutes | Economic dispatch, quick-start units, unit commitment, reserve re-procurement | Frees regulation and contingency reserves so the system can survive the next loss | NERC BAL-002-3 Contingency Reserve Restoration Period; ISO market rules |
The source of much confusion is that the stages overlap. Inertial response begins at the instant of the trip and continues — with declining contribution — until the nadir. Primary response starts within a fraction of a second, overlaps inertia completely and remains in place until AGC relieves it. Secondary control begins within seconds of the event in the AGC cycle, but its effect builds over minutes. A well-drawn frequency plot shows one continuous trajectory, not four separate steps.
What Keentel's analysis shows
Keentel modeled a 60 Hz, ERCOT-scale system with about 50 GW of load and a 2,750 MW resource loss — the size of the ERCOT resource contingency used in
BAL-003. Governors have 5% droop and a ±0.036 Hz deadband, consistent with FERC Order No. 842, with about 7,050 MW/Hz of combined governor response; load damping adds about 1,250 MW/Hz. AGC acts on area control error with a slow integral characteristic. Three cases were run.
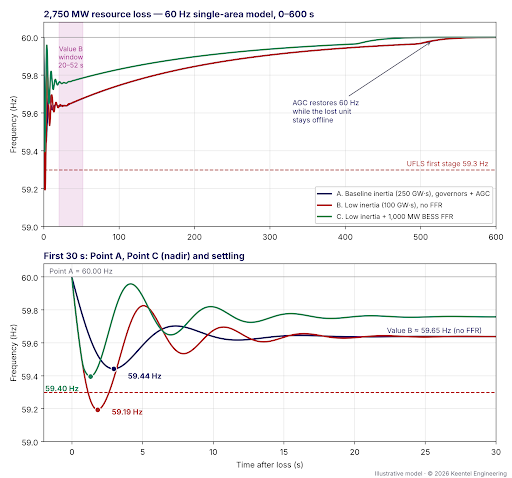
Figure 1. Keentel's single-area simulation of a 2,750 MW resource loss. Top: the full 10-minute recovery, with the BAL-003 Value B averaging window (20–52 s after the event) and AGC restoration. Bottom: the first 30 seconds, showing Point A (pre-event frequency), Point C (the nadir) and settling. The knee in the recovery near 59.96 Hz occurs where frequency re-enters the governor deadband and AGC alone completes the restoration. Case B is shown without load shedding to illustrate the margin lost; in reality, under-frequency load shedding would operate.
| Result | A. Baseline inertia (250 GW·s) | B. Low inertia (100 GW·s) | C. Low inertia + 1,000 MW BESS FFR |
|---|---|---|---|
| Initial RoCoF | 0.33 Hz/s | 0.83 Hz/s | 0.83 Hz/s |
| Nadir (Point C) | 59.44 Hz at 3.0 s | 59.19 Hz at 1.8 s | 59.40 Hz at 1.3 s |
| Margin to 59.3 Hz first UFLS stage | +0.14 Hz | −0.11 Hz (load shedding) | +0.10 Hz |
| Settling frequency, Value B (20–52 s average) | 59.65 Hz | 59.65 Hz | 59.77 Hz |
| Frequency back above 59.98 Hz (AGC) | about 8.6 min | about 8.6 min | about 7.2 min |
| Lost unit still offline at the end? | Yes | Yes | Yes |
Five results stand out:
- Inertia changes the path, not the settling point. Cases A and B settle at the same Value B, because settling frequency depends on droop and load damping, not inertia. But case B falls 2.5 times faster and reaches a nadir below the first load-shedding stage.
- Fast frequency response rescues the nadir. 1,000 MW of battery response, at full output within 0.5 s of a 59.7 Hz trigger, lifts the low-inertia nadir by 0.2 Hz — back above the load-shedding threshold — and raises Value B as well.
- Primary response leaves an offset; it does not restore 60 Hz. With 2,750 MW lost and about 8,300 MW/Hz of combined response, frequency settles about 0.36 Hz low (including the deadband effect). Only AGC removes that offset.
- Recovery happens while the shortfall persists. In every case the failed unit stays offline. Frequency returns to 60 Hz because other units' output has been raised by 2,750 MW — first by governors, then by AGC and reserve deployment.
- The clock is set by standards. In this model AGC restores frequency in under nine minutes, inside the 15-minute Contingency Event Recovery Period in NERC BAL-002-3. A balancing authority that lacks reserves cannot meet that clock, regardless of how good its governors are.
Engineering review of common statements about frequency recovery
| Statement often heard | Keentel's check |
|---|---|
| "Nominal frequency (50 Hz / 60 Hz)" | All four North American interconnections operate at 60 Hz. US examples should be drawn at 60 Hz, with UFLS thresholds such as 59.5 Hz (Eastern and Western) and 59.3 Hz (ERCOT). |
| "Primary response stabilizes frequency, though it leaves a steady-state offset (nadir)." | Two different quantities are being conflated. The nadir (Point C) is the lowest frequency, reached within seconds. The settling frequency (Value B in NERC terms) is the quasi-steady level after primary response, measured 20–52 s after the event. The nadir is always lower than Value B. |
| "Stage 2: inertial response" follows "Stage 1: initial frequency decline." | Inertial response is not a later stage. It is the physics that sets the initial decline, from the first instant. The RoCoF at t = 0 is determined entirely by the lost power and the stored kinetic energy. |
| "Inverter-based resources have no inherent inertia unless equipped with fast active power controls." | Partly right. Grid-following inverters provide no inherent inertia. Fast active power control provides fast frequency response, which is not inertia: it is a controlled injection triggered by measured frequency, with some delay. Grid-forming inverters can provide inertia-like (synthetic) response. And primary frequency response from solar or wind requires headroom — a plant at maximum output cannot increase. |
| "Only secondary response restores frequency." | Correct, with nuance. In the US, secondary control is AGC acting on ACE, which includes both frequency and tie-line interchange error. In a multi-area interconnection, AGC in the balancing authority that lost the unit does most of the work; AGC elsewhere returns other areas to schedule. |
| "Frequency can recover even if the faulted plant remains offline, provided there are sufficient reserves." | Correct, and the most important point. Without enough primary reserve, frequency falls to load-shedding thresholds. Without enough contingency reserve, AGC cannot restore 60 Hz, and the balancing authority fails BAL-002. |
| "Grid Control Centre" | US terminology is "control center"; frequency control in the US is performed by balancing authorities (BAs), coordinated by reliability coordinators. |
Five lessons
- Think of four jobs, not four steps. Inertia buys time, primary response arrests and holds, secondary response restores and tertiary action resets. Each job needs its own resources.
- Grade the nadir and the settling frequency separately. The nadir is set by inertia and response speed; Value B is set by the amount of droop response and load damping. Different fixes apply to each.
- AGC is an accounting system as well as a control system. ACE tells each balancing authority whether it is causing or helping the problem. The BA that lost the unit carries the obligation to replace it.
- Headroom is the price of response. Governors, solar, wind and batteries can only respond with the capacity they hold back. Reserve requirements are where frequency stability becomes an economic decision.
- Inverter-based resources can be the fastest responders on the system — if they are specified, set and verified to respond.
Part B — Technical Guide: From Nadir to Nominal
1. The US frequency control landscape
North America has four synchronous interconnections. Within each, every generator turns in lockstep, and a single frequency describes the whole system. Between them, power flows only through DC ties, which do not share frequency.
| Interconnection | Approximate scale | Key frequency characteristics |
|---|---|---|
| Eastern | Largest; most of the US and Canada east of the Rockies | Very high inertia; dozens of balancing authorities; first UFLS stage typically around 59.5 Hz |
| Western | US and Canada west of the Rockies, plus northern Baja California | Long transmission paths, large hydro fleet; first UFLS stage around 59.5 Hz; WECC-specific automatic time error correction in ACE |
| ERCOT (Texas) | Most of Texas; a single balancing authority | Smaller, very high wind and solar penetration, limited DC ties; first UFLS stage 59.3 Hz; real-time inertia monitoring and fast frequency response products |
| Québec | Province of Québec | Hydro-dominated, connected to its neighbors only by DC; much lower UFLS thresholds than the others |
Each interconnection is divided into balancing authorities (BAs), which balance generation, load and scheduled interchange within their areas. Reliability coordinators oversee wide-area reliability. Frequency is a shared, interconnection-wide quantity, but the obligation to respond and to replace a lost resource is assigned to individual BAs by the NERC BAL standards.
The UFLS values above are typical first-stage settings. Confirm the current regional criteria under NERC PRC-006 and the applicable regional standard before relying on them.
2. What happens at the instant of the loss
2.1 Power balance becomes energy balance
Before the trip, mechanical power into all generators equals electrical power out, plus losses. When a unit trips, the electrical load does not change in that first instant, but the mechanical input falls by the unit's output, ΔP. The difference is drawn from the kinetic energy stored in the rotating masses of every synchronous machine. The center-of-inertia swing equation describes the result:
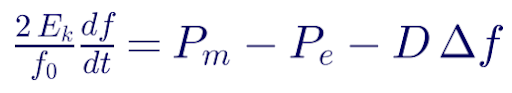
where E_k is the total stored kinetic energy of online synchronous machines (MW·s), f0 is 60 Hz, D is the load damping in MW/Hz and Δf is the frequency deviation. Stored energy is the sum of each machine's inertia constant H times its MVA rating:
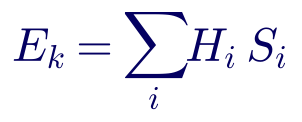
2.2 Initial rate of change of frequency
At t = 0, the governors and load have not yet changed, so the initial RoCoF depends only on ΔP and E_k:
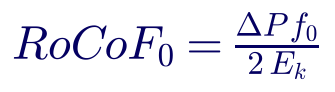
Worked example 1 — RoCoF in an Eastern-scale and an ERCOT-scale system
For an Eastern-scale illustration, take a 4,500 MW loss — the Eastern Interconnection resource contingency used in BAL-003 — and an illustrative stored energy of 2,500 GW·s:
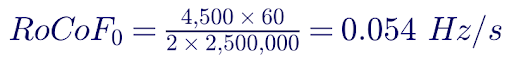
Even at 1,500 GW·s, the initial RoCoF is only 0.09 Hz/s. The Eastern Interconnection is so large that inertia rarely limits it.
For an ERCOT-scale system, a 2,750 MW loss with 250 GW·s gives 0.33 Hz/s; with 100 GW·s — a low-inertia, high-renewable hour — it gives 0.83 Hz/s. If frequency kept falling at the initial rate, it would reach 59.3 Hz in only 2.1 s and 0.85 s respectively. Real trajectories curve as response arrives, but the numbers show why ERCOT watches inertia closely and why the speed of the next stage matters so much more there than in the East.
Keentel's companion article on grid inertia covers inertia constants, synthetic inertia and synchronous condensers in detail. The remainder of this guide follows what happens next.
3. Primary frequency response: arresting the fall
3.1 The sources of primary response
Primary frequency response is any automatic, locally controlled change in power that opposes the frequency deviation. In the US it comes from:
- Governors on synchronous units. Steam, combustion turbine, combined-cycle and hydro governors respond in proportion to frequency deviation outside a deadband. Response begins within a fraction of a second; full response takes several seconds (combustion turbines and hydro) to tens of seconds (some steam units). Units running at maximum output, or with governors blocked or operating in load-control modes, contribute little or nothing.
- Inverter-based resources (IBRs). Solar, wind and batteries with frequency droop enabled change output through their plant controllers or inverter controls. Batteries can respond in both directions within a fraction of a second. Solar and wind can reduce output immediately, but can increase output only if they are operating below their available power.
- Fast frequency response (FFR). Very fast, often triggered, injections or load reductions — typically from batteries or interruptible load — that reach full output within about 0.5 s or less.
- Load damping. Motor loads draw less power at lower frequency. A typical figure is 1–2% of load per 1% change in frequency.
3.2 Droop and deadband
A droop characteristic sets how much a resource changes output for a given frequency deviation. FERC Order No. 842 requires newly interconnecting generators, including IBRs, to have primary frequency response capability with a maximum droop of 5% and a deadband no wider than ±0.036 Hz. Outside the deadband the response is:
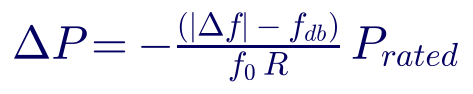
where R is the droop (0.05) and f_db is the deadband. For each 0.1 Hz beyond the deadband, a 5% droop gives 3.33% of rating. Order No. 842 does not require a resource to hold headroom; it requires the capability and requires that the resource respond with whatever headroom it has.
3.3 Load damping
Load damping D is usually expressed as a percentage of load per percentage of frequency. For a 50 GW load with 1.5% per 1%:
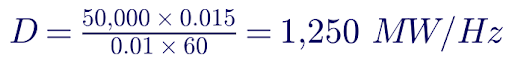
Load damping is shrinking as more motors are driven through variable-frequency drives and more load is power electronics, which draw constant power regardless of frequency. Studies should not assume historical damping values for future systems.
3.4 The nadir: where inertia meets response
The nadir — Point C in NERC terminology — is the lowest frequency reached. It occurs at the instant when the combined primary response plus load damping first equals the lost power, so that df/dt = 0. Inertia determines how far frequency falls while response is building; the speed and amount of response determine when the fall stops. The nadir is therefore sensitive to:
- the size of the loss;
- system inertia;
- the delay and ramp rate of governors and IBR controls;
- governor deadbands and the share of units actually responding;
- FFR trigger levels and speed.
3.5 The settling frequency: Value B
Once the oscillations die out, frequency settles at a level where primary response plus load damping exactly equal the lost power. Ignoring deadbands:
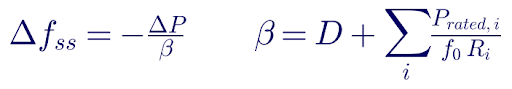
where β is the frequency response characteristic of the interconnection, in MW/Hz. NERC expresses β in MW per 0.1 Hz, so a β of 8,300 MW/Hz is 830 MW/0.1 Hz. Inertia does not appear in this equation: it shapes the path, not the destination.
Worked example 2 — settling frequency with deadband
In Keentel's model, governors contribute 7,050 MW/Hz beyond the 0.036 Hz deadband and load damping contributes 1,250 MW/Hz with no deadband. Settling occurs where:
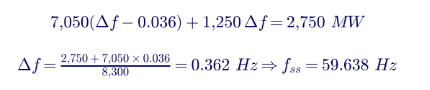
The simulation's Value B (59.65 Hz, averaged from 20 to 52 s) is slightly higher because AGC has already begun to act within that window. Without AGC, the model settles at 59.638 Hz — matching the hand calculation.
4. How NERC measures primary frequency response: BAL-003-2
4.1 Point A, Point C and Value B
NERC Reliability Standard BAL-003-2 evaluates frequency response using actual events. Each qualifying event is characterized by three points on the frequency trace:
| Measure | Definition (BAL-003 practice) | What it reflects |
|---|---|---|
| Point A | Average frequency over the 16 seconds before the event (from t − 16 s to t − 2 s) | Pre-event frequency |
| Point C | The lowest frequency (nadir) in the period immediately after the event, typically within the first 12 seconds | Inertia, speed of response and FFR |
| Value B | Average frequency from t + 20 s to t + 52 s | Settled primary response, before significant AGC action |
A BA's measured frequency response for an event is the change in its net interchange (the extra power it exported to help) divided by the frequency change from Point A to Value B, in MW/0.1 Hz. NERC uses the median of a year of qualifying events to evaluate each BA. Confirm the current event-selection and averaging details in the BAL-003-2 procedure documents before relying on them.
4.2 The Interconnection Frequency Response Obligation
NERC calculates, for each interconnection, an Interconnection Frequency Response Obligation (IFRO): the minimum frequency response needed so that the design-basis resource loss will not cause the frequency to fall to the first UFLS stage, after allowing for statistical variation and the difference between the nadir and Value B. Conceptually:
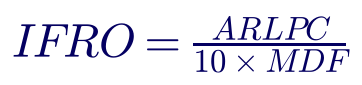
where ARLPC is the adjusted resource loss protection criterion (the design-basis loss less any credit for load resources that trip on under-frequency) and MDF is the maximum allowable delta frequency between Value B and the starting point, in Hz, after deducting margins for the nadir-to-settling ratio and starting-frequency variation.
| Interconnection | Resource contingency criterion (RLPC) | First UFLS stage (typical) |
|---|---|---|
| Eastern | 4,500 MW | about 59.5 Hz |
| Western | 2,626 MW (loss of two large nuclear units) | about 59.5 Hz |
| ERCOT | 2,750 MW | 59.3 Hz |
| Québec | about 1,700 MW | much lower, around 58.5 Hz |
These criteria and thresholds come from the BAL-003 framework and regional programs; NERC recalculates the IFROs annually in its frequency response analysis. Confirm current values before using them.
Worked example 3 — what an IFRO implies
The Eastern Interconnection IFRO has been on the order of 1,000 MW/0.1 Hz. With 4,500 MW and no load-resource credit:
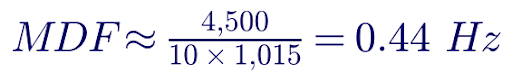
That is the largest settled deviation the obligation allows. Actual Eastern frequency response has typically been much larger than the obligation — 2,500 MW/0.1 Hz or more — so a 4,500 MW loss settles only about 0.18 Hz low.
ERCOT's IFRO has been on the order of 380 MW/0.1 Hz, smaller than one might expect for a 2,750 MW criterion. The reason is the credit for load resources that trip automatically on under-frequency: subtracting about 1,400 MW of credit leaves roughly 1,350 MW, and 1,350 / (10 × 0.354) ≈ 381 MW/0.1 Hz. The IFRO is a minimum for compliance, not a design target. Real planning studies use full dynamic models.
4.3 How the obligation is shared
Each BA receives a Frequency Response Obligation (FRO), a share of the IFRO based on its generation and load. Each BA also sets a frequency bias, B, used in its ACE calculation (section 6). BAL-003-2 ties the two together: the bias setting should reflect the BA's actual natural frequency response, so that AGC neither fights nor ignores primary response.
5. Inverter-based resources in the primary stage
5.1 What IBRs can and cannot do
| Capability | Grid-following solar or wind | Grid-following battery | Grid-forming battery |
|---|---|---|---|
| Inherent inertia | None | None | Inertia-like response from its voltage-source behavior, within current and energy limits |
| Fast frequency response | Downward only, unless curtailed | Yes, both directions, typically within 0.5 s of trigger | Yes, inherent and fast |
| Primary frequency response (droop) | Downward always; upward only with headroom | Yes, both directions, within state of charge and power limits | Yes |
| Sustained response | Depends on resource availability (sun, wind) | Limited by stored energy | Limited by stored energy |
| Over-frequency response | Yes — curtailment is easy | Yes — charging | Yes |
The difference between inertia and fast frequency response matters. Inertia responds to the rate of change of frequency without measurement or delay. FFR responds to measured frequency (or RoCoF) after a detection and ramp delay, typically a few hundred milliseconds. Both improve the nadir; FFR can deliver much more power than synthetic inertia, but only after its delay. Grid-forming inverters behave more like synchronous machines and provide genuinely immediate response, which matters most at the very start of the event.
Worked example 4 — a solar plant with headroom versus a battery
A 200 MW solar plant operates at 180 MW — 10% headroom — with 5% droop and the Order No. 842 deadband. A 100 MW battery provides FFR at full output within 0.5 s of a 59.7 Hz trigger.
| Frequency | Solar droop response (5%, ±0.036 Hz) | Battery FFR | Battery if on 5% droop instead |
|---|---|---|---|
| 59.80 Hz | +10.9 MW | 0 MW (not triggered) | +5.5 MW |
| 59.70 Hz | +17.6 MW | +100 MW within 0.5 s | +8.8 MW |
| 59.50 Hz | +20.0 MW (headroom limit; droop would ask for 30.9 MW) | +100 MW | +15.5 MW |
The battery on FFR delivers five times more power, and much faster, than the curtailed solar plant — and the solar plant pays for its headroom with 20 MW of lost energy production every hour it is curtailed. That is why ISOs procure fast response from batteries and load resources, and why solar and wind usually provide upward primary response only when they are already curtailed for other reasons.
6. Secondary control: area control error and AGC
6.1 Why primary response is not enough
Primary response stops the fall, but it leaves the interconnection off-nominal and leaves every responding unit operating away from its economic dispatch point. It also leaves tie-line flows distorted: when a unit in one BA trips, governors throughout the interconnection respond, so neighboring BAs export power to the BA that lost the unit. Secondary control resolves all three problems.
6.2 The ACE equation
Each BA's AGC computes area control error every few seconds. Under NERC BAL-001-2:

where NI_A and NI_S are actual and scheduled net interchange (MW, exports positive), B is the BA's frequency bias setting in MW/0.1 Hz (a negative number), F_A and F_S are actual and scheduled frequency (Hz), and I_ME is a meter-error correction. BAs in the Western Interconnection add an automatic time error correction term, I_ATEC. A negative ACE means the BA is under-generating; AGC raises its generation.
The frequency-bias term is the clever part. If B matches the BA's actual natural frequency response, then a BA that did not cause the disturbance sees its extra exports exactly cancelled by the bias term — its ACE stays near zero, and its AGC does not withdraw the help its governors are giving. The BA that lost the unit sees an ACE equal to the lost megawatts, and its AGC replaces them.
Worked example 5 — ACE in two balancing authorities
Consider an interconnection with a total frequency response of 2,500 MW/0.1 Hz. Balancing Authority A, with a bias of −300 MW/0.1 Hz matching its natural response, loses a 1,000 MW unit. The interconnection settles at:
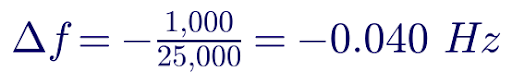
Area A's own governors supply its share, 300/2,500 × 1,000 = 120 MW. The remaining 880 MW flows in from neighbors, so A's net interchange falls 880 MW below schedule:

The rest of the interconnection, with a combined bias of −2,200 MW/0.1 Hz, exports 880 MW above schedule:

Area A's ACE is exactly its lost generation; every other area's ACE is zero. Area A's AGC and contingency reserves replace the 1,000 MW; as they do, frequency rises, the neighbors' governors back down, and tie-line flows return to schedule. Frequency recovers to 60 Hz while the tripped unit remains offline — the replacement megawatts come from other units in Area A.
If B is set too small in magnitude relative to natural response, neighbors' AGC sees a positive ACE and pulls back their help prematurely, delaying recovery. That is why BAL-003 links bias settings to measured frequency response.
6.3 AGC in practice
AGC typically runs on a 2–6 second cycle. It filters ACE, allocates the required change among regulating units according to their participation factors and ramp rates, and sends raise or lower signals. In ISO markets, AGC dispatches regulation service, and the real-time market redispatches energy every five minutes. Restoring a large deficit therefore takes minutes, not seconds: the speed is limited by unit ramp rates, the amount of regulation and contingency reserve deployed, and deliberate filtering to avoid chasing noise.
7. How NERC measures secondary control: BAL-001-2
BAL-001-2 sets two performance measures for normal operation:
- Control Performance Standard 1 (CPS1) evaluates, over a rolling 12 months, how ACE correlates with frequency error. A BA that helps frequency when it is off-nominal scores well; one whose ACE pushes frequency further away scores poorly. The requirement is a CPS1 of at least 100%.
- Balancing Authority ACE Limit (BAAL) sets frequency-dependent bounds on ACE. The further frequency is from 60 Hz, the tighter the limit on ACE in the direction that worsens it. A BA must not exceed its BAAL for more than 30 consecutive clock minutes.
BAL-001 governs everyday balancing. Large disturbances are handled by BAL-002.
8. Recovering from the contingency: BAL-002-3
The Disturbance Control Standard, BAL-002-3, applies to Reportable Balancing Contingency Events — sudden losses of generation or import above a threshold defined in the standard. For each such event, the responsible BA (or its reserve sharing group) must:
- recover ACE to zero, or to its pre-event value if that was negative, within the Contingency Event Recovery Period of 15 minutes; and
- restore its contingency reserve within the Contingency Reserve Restoration Period, 90 minutes after the end of the recovery period, so that it can withstand the next event.
BAL-002 is what makes the answer to "can frequency recover while the unit is still offline?" an obligation rather than a hope. The BA must carry enough contingency reserve to cover its most severe single contingency, and it must deploy it within 15 minutes.
Worked example 6 — reserve deployment for a 1,000 MW loss
Area A in worked example 5 must bring 1,000 MW of replacement generation online within 15 minutes. If the reserve comes from spinning units ramping in parallel, it needs an average combined ramp of at least:
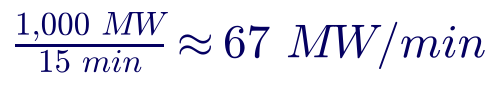
In practice the BA plans for a faster ramp, because AGC filtering, communication delays and slower units eat into the 15 minutes. If part of the reserve comes from quick-start combustion turbines that need 10 minutes to reach full load, the spinning portion must cover the shortfall until they arrive. After recovery, the BA has 90 minutes to restore its contingency reserve — by committing additional units, re-dispatching, arranging emergency purchases or, in extreme cases, shedding interruptible load.
9. Tertiary control and returning to normal
Tertiary control is the slower, mostly economic layer that follows AGC:
- Economic dispatch. In ISO markets, the security-constrained economic dispatch runs every five minutes and moves the replacement megawatts from regulating units to the least-cost available units, freeing regulation capacity.
- Reserve restoration. Units that supplied spinning reserve are released, and new reserve is designated. Quick-start units may be committed for the rest of the operating hour.
- Unit commitment. If the tripped unit will be out for days, the day-ahead and reliability commitment processes replace it.
- Time error correction. Frequency below 60 Hz for several minutes makes synchronous clocks run slow. Time error is now managed under industry business practices rather than a NERC reliability standard, using small scheduled frequency offsets; the Western Interconnection uses automatic time error correction in ACE.
9.1 What "recovered" really means
When frequency returns to 60 Hz and ACE returns to zero, the system has recovered its balance, not its security. Three things are still different from the moment before the trip:
- Reserves are depleted. The megawatts that replaced the lost unit came out of regulation and contingency reserve. Until those reserves are restored, a second contingency of the same size could not be covered. This is why BAL-002 has a separate 90-minute reserve restoration requirement.
- Flows have changed. The replacement generation is in different locations from the lost unit. Transmission flows, voltage profiles and post-contingency loadings may be worse than before, and operators may need to re-dispatch to respect system operating limits under the TOP and IRO standards.
- The failed unit is still out. Its owner must investigate the trip, and if the trip was caused by protection or control misbehavior during a disturbance, it may become a NERC event analysis or a misoperation review.
9.2 The same chain in reverse: over-frequency
A sudden loss of load — for example, a large data center or industrial site tripping offline during a transmission fault — produces the mirror image: frequency rises, inertia slows the rise, governors and IBRs reduce output, and AGC lowers generation to restore 60 Hz. Inverter-based resources are especially good at over-frequency response, because reducing output needs no headroom. As large loads grow, NERC and several ISOs are studying load-loss events and ride-through expectations for large loads, because the sudden loss of thousands of megawatts of load is now a credible contingency in some regions.
10. ERCOT: a closer look at a low-inertia interconnection
ERCOT is a single BA with limited DC ties, so it must handle every contingency internally, and its inertia varies widely with wind and solar output. ERCOT procures several ancillary services that map onto the stages in this guide:
| ERCOT service | Stage | Description (summarized; confirm current market rules) |
|---|---|---|
| Responsive Reserve Service, including Fast Frequency Response | Primary | Governor response, load resources that trip on under-frequency relays, and fast-acting resources such as batteries that deploy within a fraction of a second at a frequency trigger |
| Regulation Up and Down | Secondary | Resources following AGC signals second-to-second |
| ERCOT Contingency Reserve Service (ECRS) | Secondary and tertiary | Reserve deployable within about 10 minutes to recover frequency and replace lost generation |
| Non-Spinning Reserve | Tertiary | Offline or curtailed capacity available within about 30 minutes |
ERCOT also monitors system inertia in real time against a critical inertia level, below which existing reserves might not prevent load shedding for its 2,750 MW contingency, and procures more fast response as inertia falls. Several ERCOT events in recent years — including large simultaneous losses of inverter-based resources during transmission faults — have reinforced how much the nadir depends on fast response and ride-through.
11. Under-frequency load shedding and ride-through: the safety net
11.1 UFLS
If primary response cannot arrest the fall above the first threshold, under-frequency load shedding (UFLS) disconnects blocks of load in stages. NERC PRC-006 requires planning coordinators to develop UFLS programs meeting regional criteria, and transmission and distribution owners to implement them. Typical first stages are about 59.5 Hz in the Eastern and Western Interconnections and 59.3 Hz in ERCOT, with total shed amounts of 25–30% of load spread over several stages.
UFLS is a last resort. A system that sheds load has saved itself from collapse, but customers have lost service, and the event becomes a reliability event under NERC event analysis.
Worked example 7 — nadir margin to the first UFLS stage
Using Keentel's simulation results and ERCOT's 59.3 Hz first stage:
| Case | Nadir | Margin to 59.3 Hz | Assessment |
|---|---|---|---|
| A. Baseline inertia | 59.44 Hz | +0.14 Hz | Acceptable, but thin for a design-basis event |
| B. Low inertia, no FFR | 59.19 Hz | −0.11 Hz | UFLS would operate |
| C. Low inertia + 1,000 MW FFR | 59.40 Hz | +0.10 Hz | Restored, with modest margin |
Planners also add margin for measurement error, UFLS relay time delays, and uncertainty in governor response. A margin below about 0.1 Hz should prompt sensitivity studies with detailed models.
11.2 Ride-through
The resources that provide the response must stay connected through the event. NERC PRC-024 sets frequency and voltage protection setting boundaries for synchronous generators, and PRC-029-1 sets ride-through requirements for inverter-based resources. IEEE 2800-2022 requires transmission-connected IBRs to ride through specified frequency excursions and rates of change of frequency, and IEEE 1547-2018 sets ride-through categories for distributed resources. A resource that trips at 59.4 Hz, or on a RoCoF relay, during the event it is meant to help turns a design-basis loss into a cascading one.
12. Keentel's model and how to read it
Keentel's single-area model represents the interconnection as one equivalent machine:
- Inertia: 250 GW·s (baseline) or 100 GW·s (low).
- Governors: 7,050 MW/Hz of droop response beyond a ±0.036 Hz deadband, limited to 4,000 MW of headroom, with a 0.5 s valve lag and a 1.5 s turbine lag.
- Load damping: 1,250 MW/Hz.
- FFR: 1,000 MW triggered at 59.7 Hz, starting 0.25 s after the trigger and reaching full output 0.25 s later.
- AGC: integral control on ACE, beginning 30 s after the event.
The model is a teaching tool. It ignores network constraints, voltage dependence of load, individual governor models, unit headroom distribution and the reduction of governor response that some units exhibit after a few tens of seconds (sometimes called withdrawal). Real studies use dynamic models in positive-sequence simulation tools, validated against measured events.
13. What engineers should assess
| Item | Why it matters | How to evaluate |
|---|---|---|
| RoCoF | Determines time available before response arrives; can trip RoCoF relays | Online inertia by hour; design-basis loss; aggregate and dynamic models |
| Nadir (Point C) | Must stay above the first UFLS stage with margin | Dynamic simulation with realistic governor and IBR models; sensitivity to inertia and FFR |
| Settling frequency (Value B) | Shows whether the interconnection meets its frequency response obligation | Droop, deadband, headroom and load-damping inventory; BAL-003 event analysis |
| Inertial and fast frequency response | Main lever for nadir in low-inertia systems | FFR trigger, delay, duration and state-of-charge rules; grid-forming capability |
| Governor droop and deadband | Determines how much primary response is real | Unit settings audits; Order No. 842 compliance; detection of blocked governors and load-control modes |
| Primary response reserve | Response requires headroom | Reserve requirements and real-time headroom monitoring |
| AGC performance and restoration time | Must recover within 15 minutes | ACE and AGC tuning, regulation and contingency reserve ramp capability, BAL-001 and BAL-002 performance |
| Ride-through | Responding resources must stay online | PRC-024, PRC-029 and IEEE 2800 settings reviews |
Part C — Three Anonymous Case Studies
These composite case studies are based on the kinds of problems Keentel Engineering sees on US projects. Names, locations and details have been changed or combined, and figures are rounded.
Case study 1 — A battery fleet that was not responding the way the ISO expected
Situation. An independent power producer in Texas owned four battery storage plants, totaling 400 MW, committed to provide fast frequency response. During a large generation trip, frequency fell to about 59.6 Hz. The ISO's post-event review found that the fleet's measured response was less than half of its award, and that two plants had responded more than a second late.
Analysis. Keentel reviewed plant controller logs, disturbance monitoring records and the ISO's event data. Three issues emerged. First, two plants measured frequency at the plant controller with a heavily filtered signal, adding about 0.8 s of delay before the trigger was recognized. Second, one plant's energy management system had moved its state of charge below the level needed to sustain full output for the required duration, so the plant controller limited its response. Third, one site's frequency trigger had been set to 59.70 Hz but implemented as "below 59.70 Hz for 0.5 s", a common misreading of the service requirement.
Engineered solution. Keentel moved frequency detection to fast inverter-level or dedicated relay measurements, revised the trigger logic to remove the unnecessary time qualification, and added a state-of-charge reserve constraint tied to the awarded service. Each plant was then tested by injecting a simulated frequency signal into the plant controller and recording response at the point of interconnection.
Outcome. In the next qualifying event, the fleet delivered its full award within about 0.4 s of the trigger. The owner avoided a performance penalty and gained a documented test procedure for annual verification.
Case study 2 — A balancing authority with a bias setting that slowed recovery
Situation. A mid-sized balancing authority in the Eastern Interconnection noticed that after its own generator trips, ACE recovery took longer than expected, approaching the 15-minute limit in BAL-002-3 on two occasions. Its neighbors also reported that their AGC reacted strongly whenever the BA had a disturbance.
Analysis. Keentel analyzed several years of event data using the BAL-003 method. The BA's measured natural frequency response was about 40% larger than its frequency bias setting — the bias was based on an old generation mix with more governor-responsive steam units and had not been revisited after several unit additions. Because the bias was too small in magnitude, neighboring BAs saw positive ACE during the BA's events and withdrew their primary support early, while the BA's own AGC had to recover a larger deficit with reserves that ramped more slowly than assumed.
Engineered solution. Keentel recommended a revised bias setting consistent with measured response, a review of reserve units' actual ramp rates against the reserve plan, and an increase in fast-ramping reserve during peak hours. AGC filtering parameters were adjusted to respond faster to large ACE excursions while keeping normal regulation stable.
Outcome. After the changes, contingency recovery time for comparable events fell from about 13 minutes to about 7 minutes. The BA's CPS1 score improved, and its neighbors stopped seeing large AGC swings during its events.
Case study 3 — A planning study that found the nadir problem before it happened
Situation. A utility in the Western Interconnection was planning the retirement of two large coal units and the addition of about 1,500 MW of solar and 600 MW of batteries. The steady-state and transient stability studies were acceptable, but the transmission planner asked whether frequency performance for the design-basis loss would remain acceptable in low-load, high-solar hours.
Analysis. Keentel built a frequency-performance study using positive-sequence dynamic models validated against recent measured events. The study varied commitment patterns across a year of hourly operating conditions. In spring midday hours, online inertia in the study area fell substantially, and with governor deadbands and headroom represented realistically, the regional frequency response shrank. The modeled nadir for the design-basis loss fell to within 0.05 Hz of the first UFLS stage in about 4% of hours.
Engineered solution. Keentel recommended specifying fast frequency response capability and droop settings for the new batteries in their interconnection agreements, enabling grid-forming capability on part of the battery fleet, and holding a minimum amount of upward headroom on the batteries during low-inertia hours. Primary frequency response settings were verified for all new resources under Order No. 842.
Outcome. With the recommended battery response, the minimum modeled nadir margin improved to about 0.25 Hz in all hours. The utility incorporated the battery settings into its procurement specifications and added frequency-performance screening to its annual planning cycle.
Part D — 20-Question Technical FAQ
1. Can grid frequency return to 60 Hz while the generation that tripped is still offline?
Yes. Frequency recovers because other resources replace the lost output — partly and automatically through primary response, then fully through AGC and contingency reserve deployment. The failed unit can stay offline for hours or days; what must be resolved is the system-wide imbalance, not the outage at that plant.
2. What are the stages of frequency response after a generation loss?
Inertial response (instantaneous, sets the initial RoCoF), primary frequency response (seconds; arrests the fall and settles frequency), secondary control or AGC (minutes; restores 60 Hz and scheduled interchange) and tertiary control (tens of minutes; re-dispatches and restores reserves). The stages overlap rather than occurring one after another.
3. What is the difference between the nadir and the settling frequency?
The nadir (Point C) is the lowest frequency reached, usually within a few seconds. The settling frequency (Value B in BAL-003, averaged from 20 to 52 s after the event) is the quasi-steady level after primary response. The nadir is always lower. Inertia and response speed drive the nadir; droop, deadbands and load damping drive the settling frequency.
4. Why doesn't primary response bring frequency back to 60 Hz?
Droop control is proportional: a resource produces extra output only while frequency is below nominal. If frequency returned to 60 Hz, the extra output would disappear. Restoring 60 Hz needs an integral action — AGC — that changes the resources' setpoints.
5. What does BAL-003-2 require?
It requires each balancing authority to meet a frequency response obligation, measured from actual events as the change in net interchange per 0.1 Hz of frequency deviation between Point A and Value B, and to set its frequency bias consistent with its measured response.
6. What is the Interconnection Frequency Response Obligation?
The minimum frequency response, in MW/0.1 Hz, needed so the interconnection's design-basis resource loss will not drive frequency to the first UFLS stage, after allowing for margins. NERC recalculates it annually and allocates it among BAs.
7. What resource losses do US interconnections design for?
BAL-003 uses 4,500 MW for the Eastern Interconnection, 2,626 MW for the Western Interconnection, 2,750 MW for ERCOT and about 1,700 MW for Québec. Confirm current values in NERC's annual frequency response analysis.
8. What is area control error?
ACE is the BA's real-time measure of imbalance: the deviation of net interchange from schedule, minus ten times the frequency bias times the frequency error, with a meter-error correction (and automatic time error correction in the West). AGC drives ACE toward zero.
9. Why is the frequency bias term important?
It lets each BA distinguish its own imbalance from helping a neighbor. With a correct bias, a BA that is supporting the interconnection after someone else's trip sees ACE near zero and keeps helping. A bias that is too small makes neighbors withdraw support early.
10. What is BAL-002-3?
The Disturbance Control Standard. After a reportable balancing contingency event, the responsible BA must recover ACE within 15 minutes and restore its contingency reserve within a further 90 minutes.
11. What are CPS1 and BAAL?
They are the BAL-001-2 measures of everyday balancing. CPS1 rewards ACE that helps frequency over a rolling year; BAAL sets frequency-dependent limits on ACE that must not be exceeded for more than 30 consecutive minutes.
12. What do FERC Order No. 842 droop and deadband settings mean?
New generators must be capable of primary frequency response with droop no greater than 5% and a deadband no wider than ±0.036 Hz. Order No. 842 does not require resources to hold headroom, only to respond with the headroom they have.
13. Do solar and wind plants provide frequency response?
They can reduce output immediately for over-frequency and, with droop enabled, can increase output for under-frequency only if they are operating below their available power. Curtailing to hold headroom costs energy, so upward response from solar and wind is usually provided only when they are already curtailed or when markets pay for it.
14. Is fast frequency response the same as inertia?
No. Inertia is an inherent physical response to the rate of change of frequency, with no delay. Fast frequency response is a controlled injection triggered by measured frequency or RoCoF, with a short delay. FFR can deliver much more power; inertia acts first.
15. What can grid-forming inverters add?
A grid-forming inverter behaves as a voltage source and responds to frequency and phase changes immediately, providing inertia-like support within its current and energy limits. It is most valuable in low-inertia systems and weak grids.
16. How fast does AGC restore frequency?
Typically over 5 to 15 minutes, limited by ramp rates, the reserves deployed and AGC filtering. BAL-002 sets the 15-minute limit for recovering ACE after a reportable contingency.
17. What happens if there are not enough reserves?
If primary reserves are insufficient, frequency falls to UFLS thresholds and load is shed. If contingency reserves are insufficient, AGC cannot restore 60 Hz, the BA fails BAL-002, and operators may need emergency imports, interruptible load or manual load shedding.
18. Why does ERCOT focus so much on fast response?
ERCOT is a single BA with limited DC ties and high wind and solar output, so its inertia can be low and it must handle every contingency internally. It monitors inertia in real time and procures fast response from batteries and load resources to protect the nadir.
19. What ride-through requirements apply during a frequency event?
PRC-024 governs protection settings for synchronous generators, PRC-029-1 governs ride-through for inverter-based resources, IEEE 2800-2022 covers transmission-connected IBRs and IEEE 1547-2018 covers distributed resources. Resources that trip during the event worsen it.
20. What studies should a new large plant or a planning area perform?
A frequency-performance study using validated dynamic models across a range of operating conditions, verification of droop, deadband and FFR settings at commissioning, and periodic comparison with measured events. The results should show nadir margin to UFLS, settling frequency against obligations and recovery within BAL-002 limits.
Keentel Services, References and Contact
How Keentel Engineering Helps
Keentel Engineering supports utilities, balancing authorities, independent power producers and large-load developers with every stage of frequency performance:
- Frequency performance studies: aggregate and full dynamic studies of RoCoF, nadir, settling frequency and recovery for design-basis losses, across a year of operating conditions.
- Primary frequency response compliance: droop, deadband and headroom settings for synchronous units, solar, wind and batteries under FERC Order No. 842 and interconnection agreements, with commissioning tests.
- Fast frequency response and grid-forming design: trigger logic, measurement, response timing and state-of-charge management for battery fleets; grid-forming specification and EMT verification.
- BAL standards support: BAL-003 event analysis and bias-setting reviews, BAL-001 and BAL-002 performance analysis and reserve-ramp assessments.
- Ride-through and protection reviews: PRC-024, PRC-029 and IEEE 2800 settings reviews so responding resources stay online.
- Event analysis: reconstruction of frequency events using PMU, SCADA and plant data, with root cause and corrective actions.
- Model development and validation: governor, plant controller and IBR models benchmarked against field data for planning and interconnection studies.
Why Clients Choose Keentel
- System studies and plant engineering under one roof. We understand both what the interconnection needs and what a plant controller can deliver.
- US standards fluency. NERC BAL-001, BAL-002, BAL-003, PRC-006, PRC-024 and PRC-029; FERC Orders 842 and 901; IEEE 2800 and 1547.
- Evidence-based results. We validate models against recorded events and test settings in the field.
- From 4 kV to 765 kV. Distribution-connected batteries, utility-scale solar and wind, and transmission-level planning areas.
- Responsive senior engineers who stay with the project from study through commissioning.
Talk to Keentel Engineering
Planning a battery, solar or wind project with frequency response obligations, or reviewing frequency performance for your area? Keentel Engineering can help you study it, set it and prove it.
- Phone: (813) 389-7871
- Email: contact@keentelengineering.com
- Book a 15-minute call: calendly.com/keentel-engineering/15min
- Web: keentelengineering.com
References
- NERC Reliability Standard BAL-001-2, Real Power Balancing Control Performance.
- NERC Reliability Standard BAL-002-3, Disturbance Control Standard — Contingency Reserve for Recovery from a Balancing Contingency Event.
- NERC Reliability Standard BAL-003-2, Frequency Response and Frequency Bias Setting, and associated procedure documents.
- NERC, annual Frequency Response Annual Analysis.
- NERC Reliability Standards PRC-006 (Automatic Underfrequency Load Shedding), PRC-024 (Frequency and Voltage Protection Settings) and PRC-029-1 (Frequency and Voltage Ride-through Requirements for Inverter-Based Resources).
- NERC Reliability Guideline, Primary Frequency Control; NERC guidance on fast frequency response and inverter-based resource performance.
- FERC Order No. 842, Essential Reliability Services and the Evolving Bulk-Power System — Primary Frequency Response.
- FERC Order No. 901, Reliability Standards to Address Inverter-Based Resources.
- IEEE Std 2800-2022, Interconnection and Interoperability of Inverter-Based Resources Interconnecting with Associated Transmission Electric Power Systems.
- IEEE Std 1547-2018, Interconnection and Interoperability of Distributed Energy Resources with Associated Electric Power Systems Interfaces.
- ERCOT, Nodal Protocols and ancillary service methodology documents.
- Kundur, P., Power System Stability and Control, McGraw-Hill.
- Wood, A. J., Wollenberg, B. F., and Sheblé, G. B., Power Generation, Operation, and Control, Wiley.
Disclaimer
This article is provided by Keentel Engineering for general technical education. It is not engineering, operational or compliance advice for any specific system or project. The system data, inertia, governor and FFR parameters, simulation results, and case studies are illustrative or composite. Resource contingency criteria, frequency response obligations, UFLS thresholds and market products change over time; always confirm current values in the applicable NERC standards, regional criteria and ISO/RTO rules. Keentel Engineering accepts no liability for decisions made on the basis of this article without a project-specific engineering review.
© 2026 Keentel Engineering. All rights reserved. Written by Keentel Engineering.
| Office | Address | Phone |
|---|---|---|
| Head Office — Tampa | 400 N Ashley Dr STE #2600, Tampa FL 33602 | (813) 389-7871 |
| Austin | 5900 Balcones Drive STE 100, Austin TX 78731 | (512) 591-0752 |
| Sacramento | 1401 21st St Ste R, Sacramento CA 95811 | (916) 913-4524 |
| Baltimore | 306 W Redwood St STE 200, Baltimore MD 21201 | (410) 225-2181 |
About the Author:
Sandip "Sonny" R. Patel, P.E.
IEEE Senior Member · Founder & CEO, Keentel Engineering
In 1995, Sonny Patel earned his Electrical Engineering degree from the University of Illinois. But degrees don't build legacies — action does.
For three decades, he has worked the power industry from every side of the table: 16 years as a utility engineer at Exelon/Commonwealth Edison; generation leadership across hydroelectric, industrial steam turbine, and a 9 GW renewable fleet; NERC Regional Entity Senior Compliance Engineer and Audit Team Lead, auditing some of the nation's largest utilities; and testing and commissioning lead on equipment up to 765 kV — the very top of the North American grid.Utility. Generator. Regulator. Consultant. Few engineers have seen all four seats. Fewer still have sat in them.
His experience spans nuclear, hydro, conventional generation, renewables, oil and gas, mining — and today's data centers, where he is authoring a three-book series on data center design. He is a Licensed Professional Engineer in six states and a Licensed Electrical Contractor in Florida (Unlimited EC) — he doesn't just design the work; he's qualified to stand behind its execution.Today, as Founder and CEO of Keentel Engineering, Sonny leads a nationwide team of engineers delivering substation design, power system studies, NERC compliance, and commissioning — done right, coast to coast.Three decades. Every side of the table. One standard: accountable engineering.
Services
Let's Discuss Your Project
Let's book a call to discuss your electrical engineering project that we can help you with.
About the Author:
Sandip "Sonny" R. Patel, P.E.
IEEE Senior Member · Founder & CEO, Keentel Engineering
In 1995, Sonny Patel earned his Electrical Engineering degree from the University of Illinois. But degrees don't build legacies — action does.
For three decades, he has worked the power industry from every side of the table: 16 years as a utility engineer at Exelon/Commonwealth Edison; generation leadership across hydroelectric, industrial steam turbine, and a 9 GW renewable fleet; NERC Regional Entity Senior Compliance Engineer and Audit Team Lead, auditing some of the nation's largest utilities; and testing and commissioning lead on equipment up to 765 kV — the very top of the North American grid.
Utility. Generator. Regulator. Consultant. Few engineers have seen all four seats. Fewer still have sat in them.
His experience spans nuclear, hydro, conventional generation, renewables, oil and gas, mining — and today's data centers, where he is authoring a three-book series on data center design. He is a Licensed Professional Engineer in six states and a Licensed Electrical Contractor in Florida (Unlimited EC) — he doesn't just design the work; he's qualified to stand behind its execution.
Today, as Founder and CEO of Keentel Engineering, Sonny leads a nationwide team of engineers delivering substation design, power system studies, NERC compliance, and commissioning — done right, coast to coast.Three decades. Every side of the table. One standard: accountable engineering.
Leave a Comment
Thank you for contacting us.
We will get back to you as soon as possible.
We will get back to you as soon as possible.
Oops, there was an error sending your message.
Please try again later.
Please try again later.
Related Posts
By SANDIP R PATEL
•
November 5, 2026
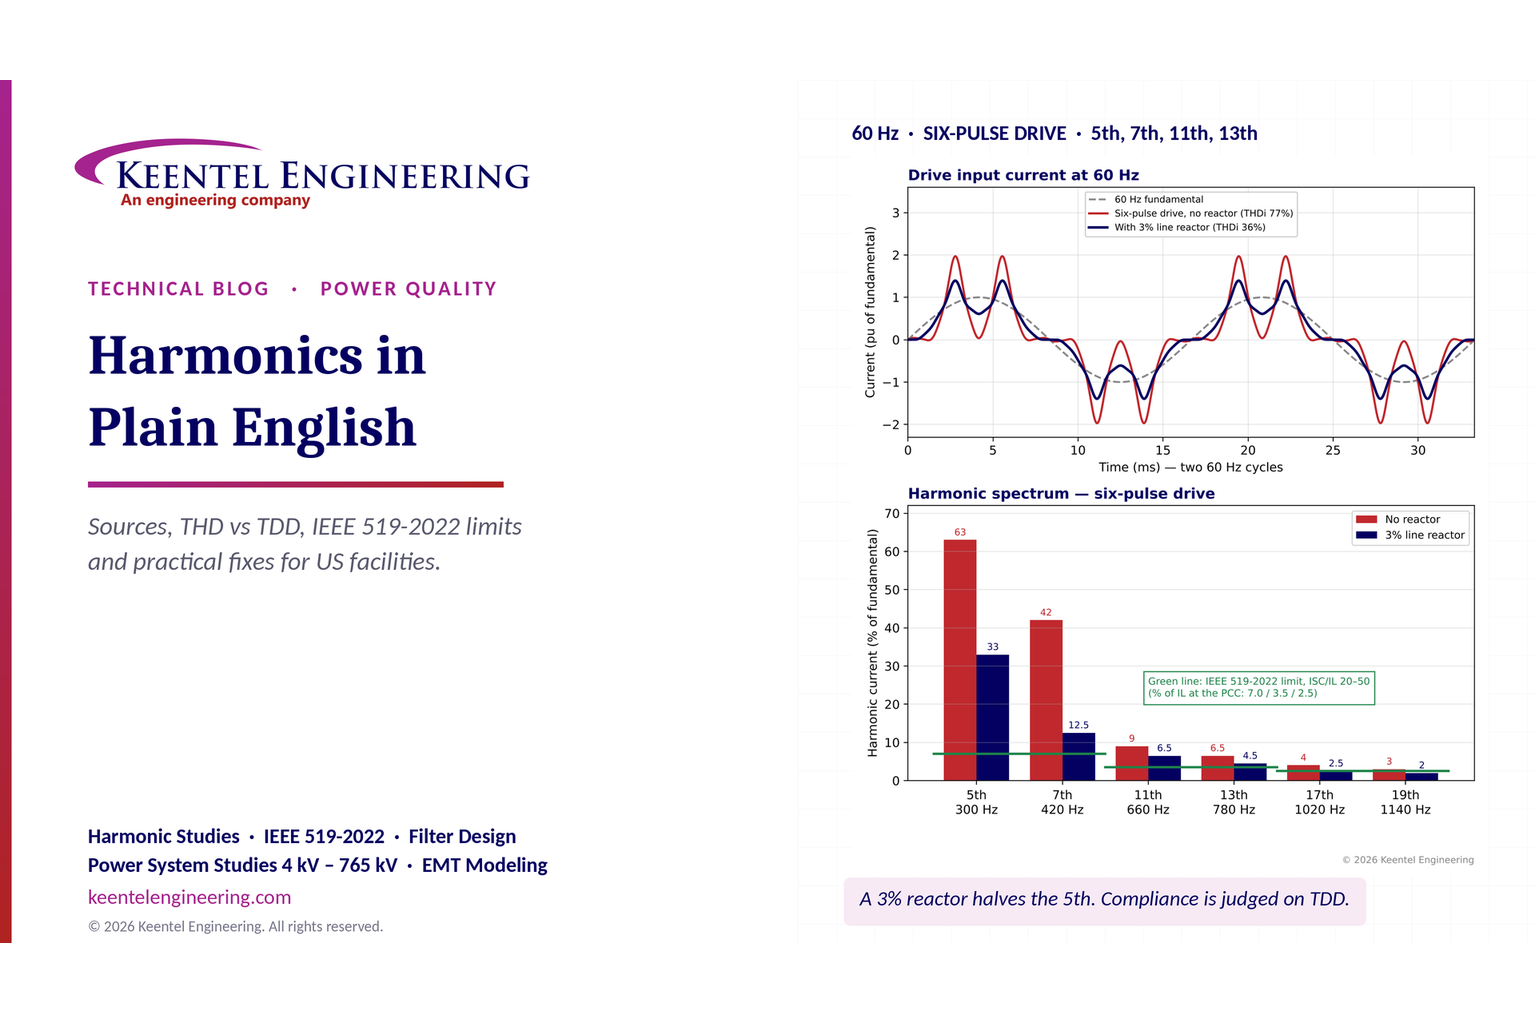
Understand electrical harmonics, THD vs TDD and IEEE 519-2022 limits. Keentel Engineering explains US harmonic studies, equipment risks and mitigation.
By SANDIP R PATEL
•
November 5, 2026
Explore solid-state transformers and MVDC for AI data centers. Keentel Engineering covers US grid interconnection, EMT modeling and protection studies.
By SANDIP R PATEL
•
November 5, 2026
Learn how 87T relays distinguish transformer inrush from internal faults, with harmonic blocking, EMT studies and US examples from Keentel Engineering.
By SANDIP R PATEL
•
October 31, 2026
Compare AIS vs GIS substations by cost, footprint, reliability, maintenance and SF6 impact. Explore design differences and life-cycle costs for US substations.
By SANDIP R PATEL
•
October 30, 2026
Protection relay site acceptance testing (SAT) guide covering CT/VT checks, secondary injection, motor relays, 87B bus differential and IEEE/NETA standards.

By SANDIP R PATEL
•
October 30, 2026
Understand SPP HILL requirements, HDPS interconnection studies, voltage and frequency ride-through, EMT modeling, weak-grid screening, and compliance.
By SANDIP R PATEL
•
October 29, 2026
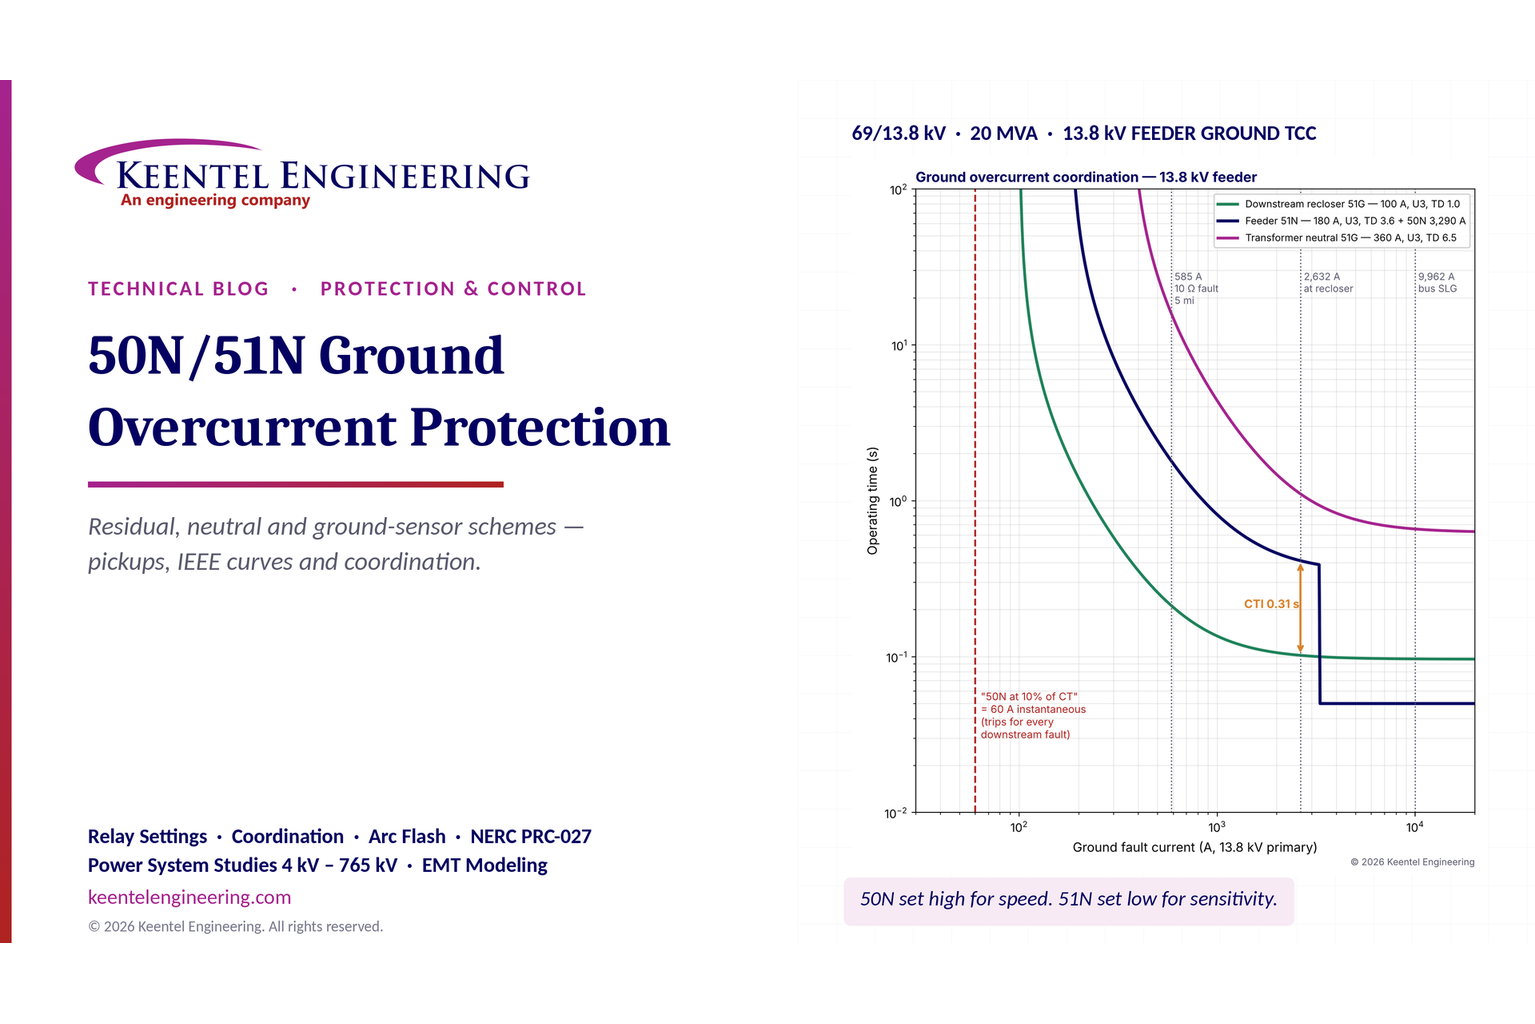
Learn 50N/51N ground overcurrent protection, relay settings, CT connections, IEEE curves, TCC coordination and ground fault protection for substations.
By SANDIP R PATEL
•
October 29, 2026
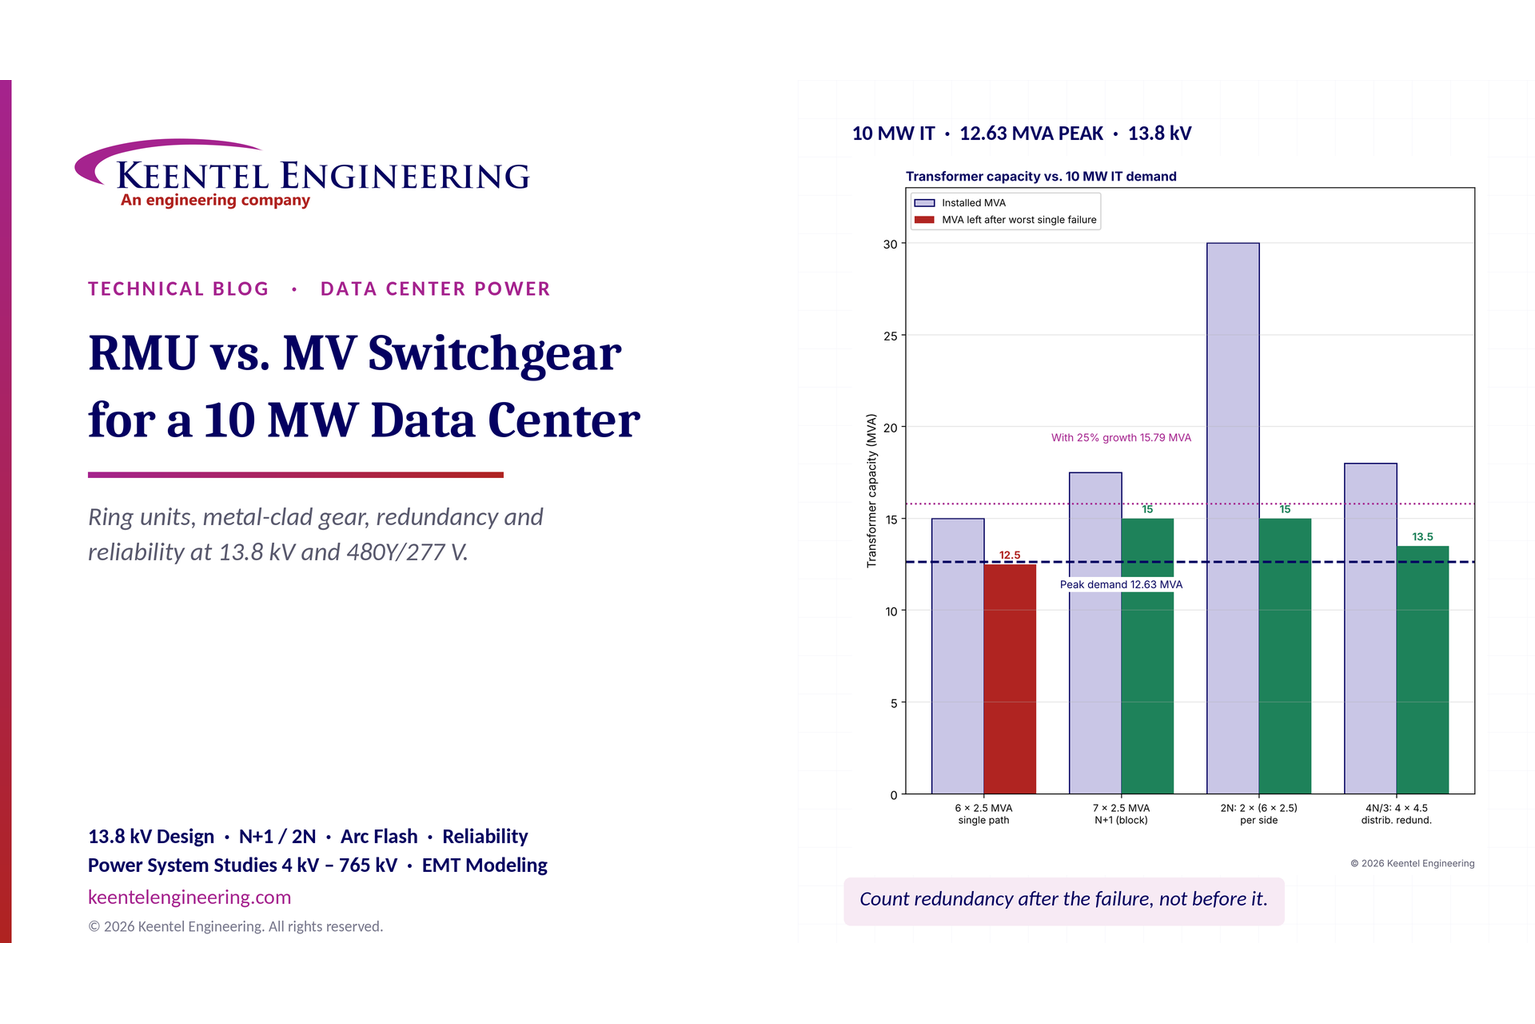
Compare RMU vs. MV switchgear for a 10 MW data center. Explore 13.8 kV design, transformer sizing, N+1/2N redundancy, arc flash and reliability.
By SANDIP R PATEL
•
October 29, 2026
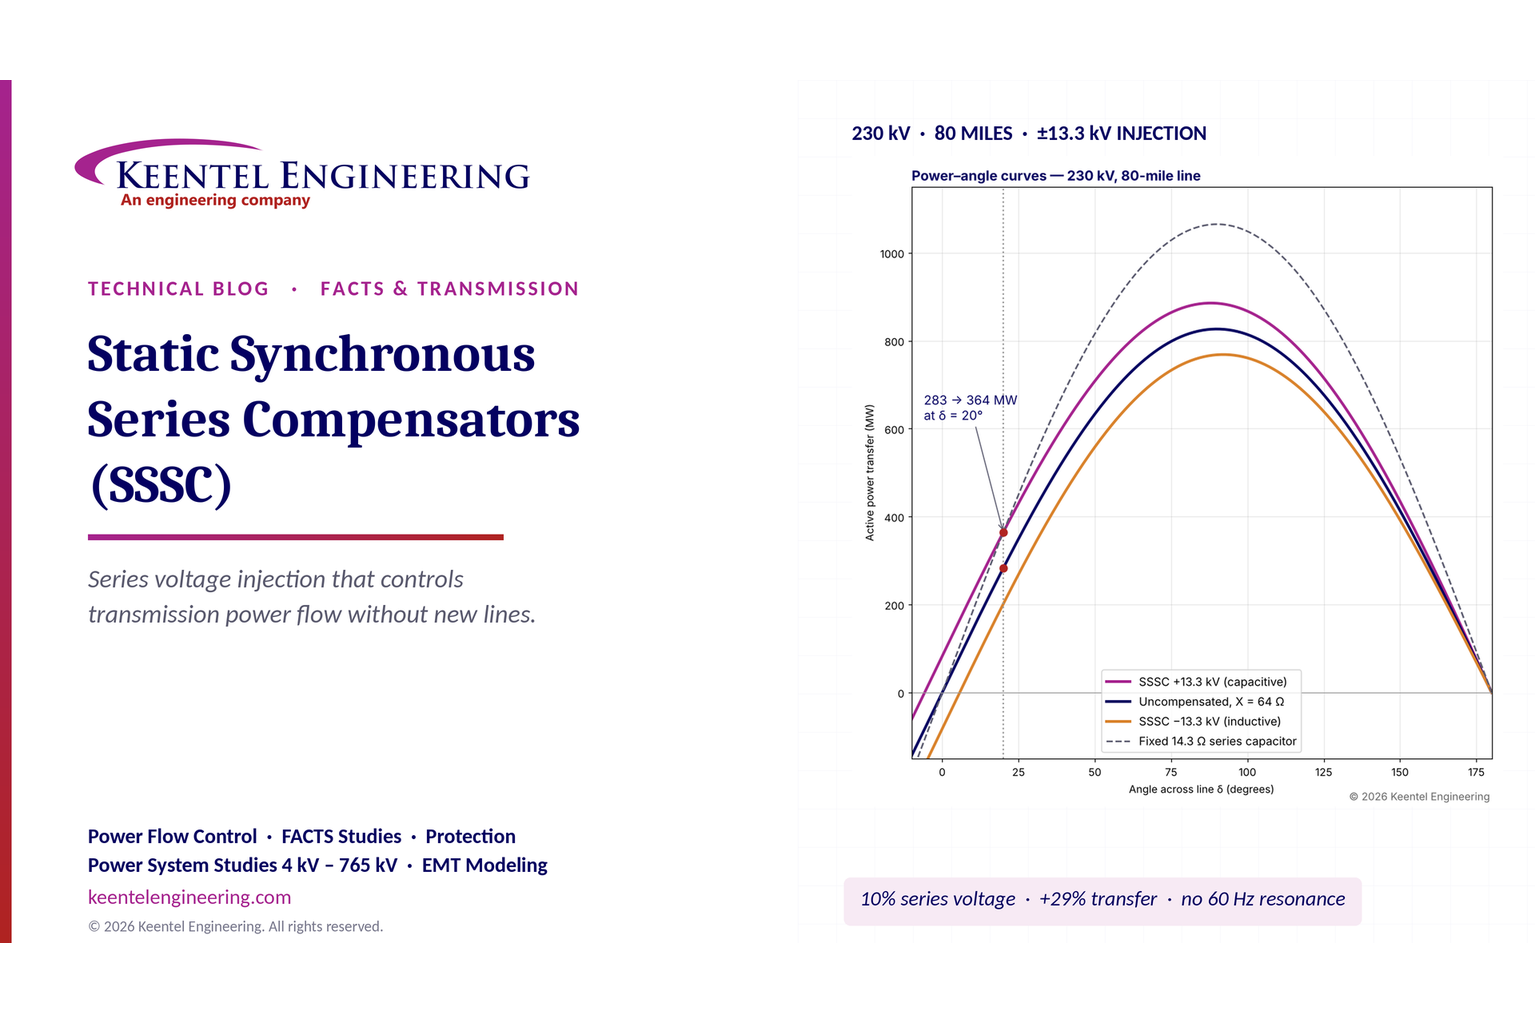
Learn how static synchronous series compensators (SSSC) control transmission power flow, improve grid stability and support FACTS applications, with examples.